Ranulfo Bezerra
Projects

Selected projects·2021 — 2024

Automation for Transformable Production

Multi-robot task allocation and control for garment manufacturing that has to reconfigure itself for every order.

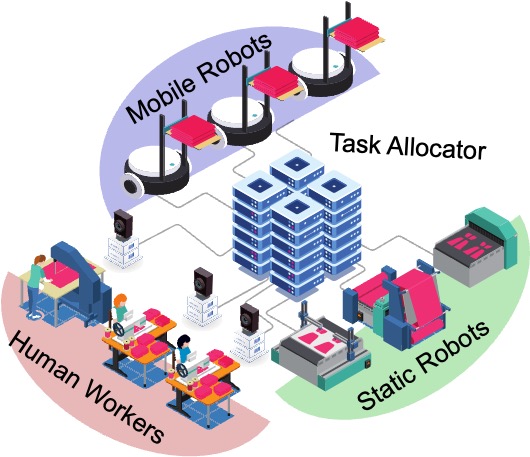
Diagram of a transformable garment production floor: mobile robots, a task allocator, static robots, and human workers.
Image: Ranulfo Bezerra

As the fashion industry shifted toward on-demand orders, Transformable Production emerged as the manufacturing model for personalised clothing: high model variety, small batches, and a factory floor that must reconfigure constantly. This project treated the floor as a heterogeneous multi-robot system — static robots, mobile transporters, and human workers — and asked how tasks should be scheduled and allocated across it. The work ran from scheduling heuristics through deep reinforcement learning to multi-agent pickup and delivery, and it is where the coordination questions in the current program were first posed concretely.
01/Representative publications

7

2023

From Mass Production to Transformable Production using Multi-robot Transportation System

Ranulfo Bezerra, Kazunori Ohno, Shotaro Kojima, Hanif Aryadi, Kenta Gunji, Masao Kuwahara, Yoshito Okada, Masashi Konyo, Satoshi Tadokoro

Book chapter·Book chapter

2022

Task Scheduling Problem for Heterogeneous Multi-Robot Garment Mass Customization

Ranulfo Bezerra, Kazunori Ohno, Shotaro Kojima, Hanif Aryadi, Kenta Gunji, Masao Kuwahara, Yoshito Okada, Masashi Konyo, Satoshi Tadokoro

ICRA 2022 Workshop·Conference

2022

PEFTST: A Heterogeneous Multi-Robot Task Scheduling Heuristic for Garment Mass Customization

Ranulfo Bezerra, Kazunori Ohno, Shotaro Kojima, Hanif Aryadi, Kenta Gunji, Masao Kuwahara, Yoshito Okada, Masashi Konyo, Satoshi Tadokoro

RSJ 2022·Domestic conference