About
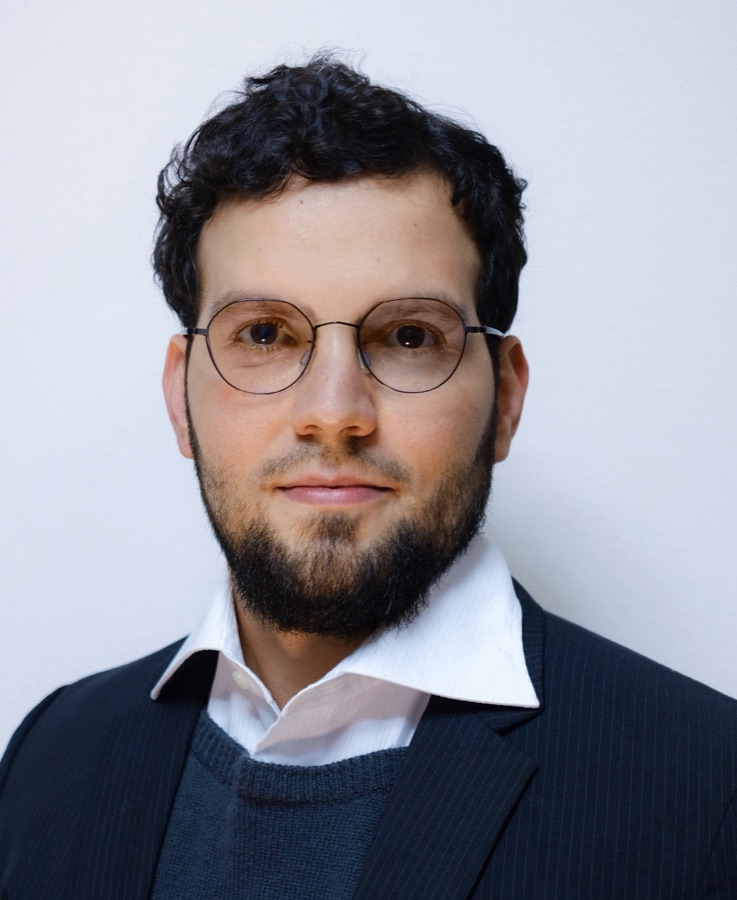
Ranulfo Bezerra
Assistant Professor · Tohoku University
Assistant Professor in the Department of Robotics, Graduate School of Engineering at Tohoku University, working within the Yamazaki–Bezerra Laboratory (Tohoku Robotic Systems Laboratory) and the Tough Cyberphysical AI Research Center. I work on reasoning-aware AI for connected robotic and sensor systems, with a focus on enabling collective intelligence under partial observability in safety-critical environments. My work centres on system-level architectures for multi-robot coordination, autonomous inspection, and distributed sensing, integrating probabilistic modelling, learning-based approaches, and semantic representations for knowledge-driven decision-making.
I received my Ph.D. in Information Sciences from Tohoku University in 2021, supervised by Prof. Satoshi Tadokoro with Prof. Kazunori Ohno as co-advisor, and my M.Sc. and B.Sc. in Computer Science from the Federal University of Piauí, Brazil, in 2018 and 2016 respectively.
Positions
2026 —
Assistant Professor
Department of Robotics, Graduate School of Engineering, Tohoku University
2022 — 2026
Specially Appointed Assistant Professor
Tough Cyberphysical AI Research Center, Graduate School of Information Sciences, Tohoku University
2021 — 2022
Specially Appointed Research Fellow
Tough Cyberphysical AI Research Center, Graduate School of Information Sciences, Tohoku University
Education
2018 — 2021
Ph.D. in Information Sciences
Tohoku University
Thesis Knowledge Acquisition Based on Traffic Behavior Analysis from Mobile Probe Data
Advisors Satoshi Tadokoro (advisor) · Kazunori Ohno (co-advisor)
2016 — 2018
M.Sc. in Computer Science
Federal University of Piauí
2010 — 2016
B.Sc. in Computer Science
Federal University of Piauí
01/Service
2026
Publication Chair
IEEE International Symposium on Safety, Security and Rescue Robotics
2023 —
Associate Editor
Journal of Internet of Things
2019 —
Reviewer
IEEE Robotics and Automation Society
02/Memberships
- IEEE Senior Member
- IEEE Robotics and Automation Society
- Robotics Society of Japan (RSJ)
03/Profiles
04/Research funding
2026 — 2028
Awarded
Interpretable Reasoning Framework for IoT–Robot Collaboration using Semantic Graphs
Japan Society for the Promotion of Science — KAKENHI, Early-Career Scientists·Principal Investigator·¥5,000,000
2026 — 2027
Awarded
Domain-Adaptive Semantic Evidence for Connected Robotics
Tough Cyber-Physical AI Research Center — Research Project·Principal Investigator·¥2,000,000
2025
Awarded
Reasoning Over IoT and Robot Vision for Hazardous Scene Understanding
NVIDIA — Academic Grant Program (DGX Spark)·Principal Investigator
2024 — 2025
Awarded
Optimizing Robot Response: Using SLMs for Robotic Data Synthesis and LLMs for Interpretation
Tough Cyber-Physical AI Research Center — Joint Research Project·Principal Investigator·¥2,000,000
2023 — 2024
Awarded
Knowledge-based Digital Twin Update using Multi-camera IoT with Federated Learning
Tough Cyber-Physical AI Research Center — Joint Research Project·Principal Investigator·¥2,000,000
2019 — 2020
Awarded
Knowledge Acquisition for Autonomous Robots from Multimodal Information
Japan Science and Technology Agency — AIP Challenge·Principal Investigator·¥1,000,000
Scholarships
2018 — 2021
Full scholarship — doctoral studies, Tohoku University
Japan Agency for Marine-Earth Science and Technology
2016 — 2018
Full scholarship — master's studies
Federal University of Piauí, Brazil
2013 — 2014
Full scholarship — exchange studies
Loyola University Chicago, USA
05/Awards
10
2025
Best Student Paper Award Finalist
IEEE SSRR 2025, Japan
Awarded to my supervised student: Nathan Pascal Walus
Semantic Enrichment of CAD-Based Industrial Environments via Scene Graphs for Simulation and Reasoning
2025
Student Encouragement Award
30th Robotics Symposia, Japan
Awarded to my supervised student: Masaki Yokota
Universal HueCode: Embedding Additional Markers into Monochrome Markers Using Optimal Color Scheme and Recognition Robust to Illumination Changes
2023
3rd Place Award
World RoboCup — Rescue Major, Japan
2022
Excellent Presentation Award
SI2022, System Integration Division, SICE, Japan
Task Allocation for Plant Inspection by Heterogeneous Robots and Evaluation in WRS2020
2022
Excellent Presentation Award
SI2022, System Integration Division, SICE, Japan
High-Precision Lightweight Simulation of Mecanum Wheels Modeling Passive Rotation Rollers via Anisotropic Friction
2022
Postgraduate Research Encouragement Award
Society of Automotive Engineers of Japan
2022
Outstanding Research Award
Graduate School of Information Sciences, Tohoku University
2021
1st Place Award
WRS Plant Disaster Prevention Challenge, Japan
2021
Measurement Automatic Control Science Award
WRS Plant Disaster Prevention Challenge, Japan
2020
Excellent Research and Technology Award
Robotics Society of Japan
06/Invited lectures
2026
Knowledge Acquisition based on Traffic Behavior Analysis using Mobile Probe Vehicle
International Symposium on Rescue Vehicles and Robots·Taipei, Taiwan
2025
Transformable Production in Garment Manufacturing: Scheduling and Layout SLAM with Mobile Robots
IEEE SII 2025 — Workshop on Systems Integration in Garment Production·Munich, Germany
2024
Artificial Intelligent Robotic Things applied to Agriculture
Brazilian DNT Congress·Teresina, Brazil
2023
From Mass Production to Transformable Production using Multi-robot Transportation System
ITC Seminar — AI and Robotics for the Garment Industry·Hong Kong
07/Teaching & supervision
Formal degree supervision is arranged within the Yamazaki–Bezerra Laboratory, led by Prof. Kimitoshi Yamazaki. I supervise or co-supervise research on the topics below.
08/Research topics for students
Students in the Yamazaki–Bezerra Laboratory may work on research topics related to Connected Robotics, distributed sensing, semantic world models, multi-robot intelligence, robot learning, and edge AI. Some examples:
- 01
Robot-deployed IoT sensing: where to place or carry a sensor when occlusion, not the map, decides what can be seen.
Collective Observability & Adaptive Sensing
- 02
Semantic scene graphs that carry uncertainty and provenance, built from CAD, cameras, and IoT streams.
Shared Semantic World Models
- 03
Evidence exchange and belief update across a robot–sensor network, with small and large language models as reasoning components.
Distributed Physical Reasoning
- 04
Explainable task allocation for heterogeneous robot teams, where every assignment can be justified to a human operator.
Explainable Collective Decision & Action
- 05
Edge inference for on-robot reasoning, trained in Isaac Sim / Isaac Lab and validated on real robots and IoT devices.
Edge Physical AI
Research is conducted in English; Japanese is not required for working with me. Admissions, deadlines, and requirements are set by Tohoku University and the laboratory.
Laboratory admissions and opportunities09/Collaboration
I am interested in academic and industry collaborations involving Connected Robotics, robot-IoT systems, distributed sensing, semantic world models, edge AI, autonomous inspection, and Physical AI.
For broader laboratory collaboration, facilities, student recruitment, and institutional information, please visit the Yamazaki–Bezerra Laboratory website.
Visit Laboratory WebsiteFrequent co-authors·derived from the publication record
Kazunori Ohno (Tohoku University)·Satoshi Tadokoro (Tohoku University)·Shotaro Kojima (Tohoku University)·Yoshito Okada (Tohoku University)·Masashi Konyo (Tohoku University)·Kenta Gunji (Tohoku University)·Masao Kuwahara (Tohoku University)·Thomas Westfechtel (University of Tokyo)·Tsige Tadesse Alemayoh (Tohoku University)·André M. Santana (Federal University of Piauí)·Kenjiro Tadakuma (Tohoku University)·Marcelo Becker (University of São Paulo)·Ricardo A. L. Rabêlo (Federal University of Piauí)·Ricardo V. Godoy (University of São Paulo)
Contact
- ranulfo@tohoku.ac.jp
- Phone
- +81 22-795-4871
- Address
- 5-5-6 Aoba Aramaki, Aoba-ku, Sendai, Miyagi 980-0845, Japan