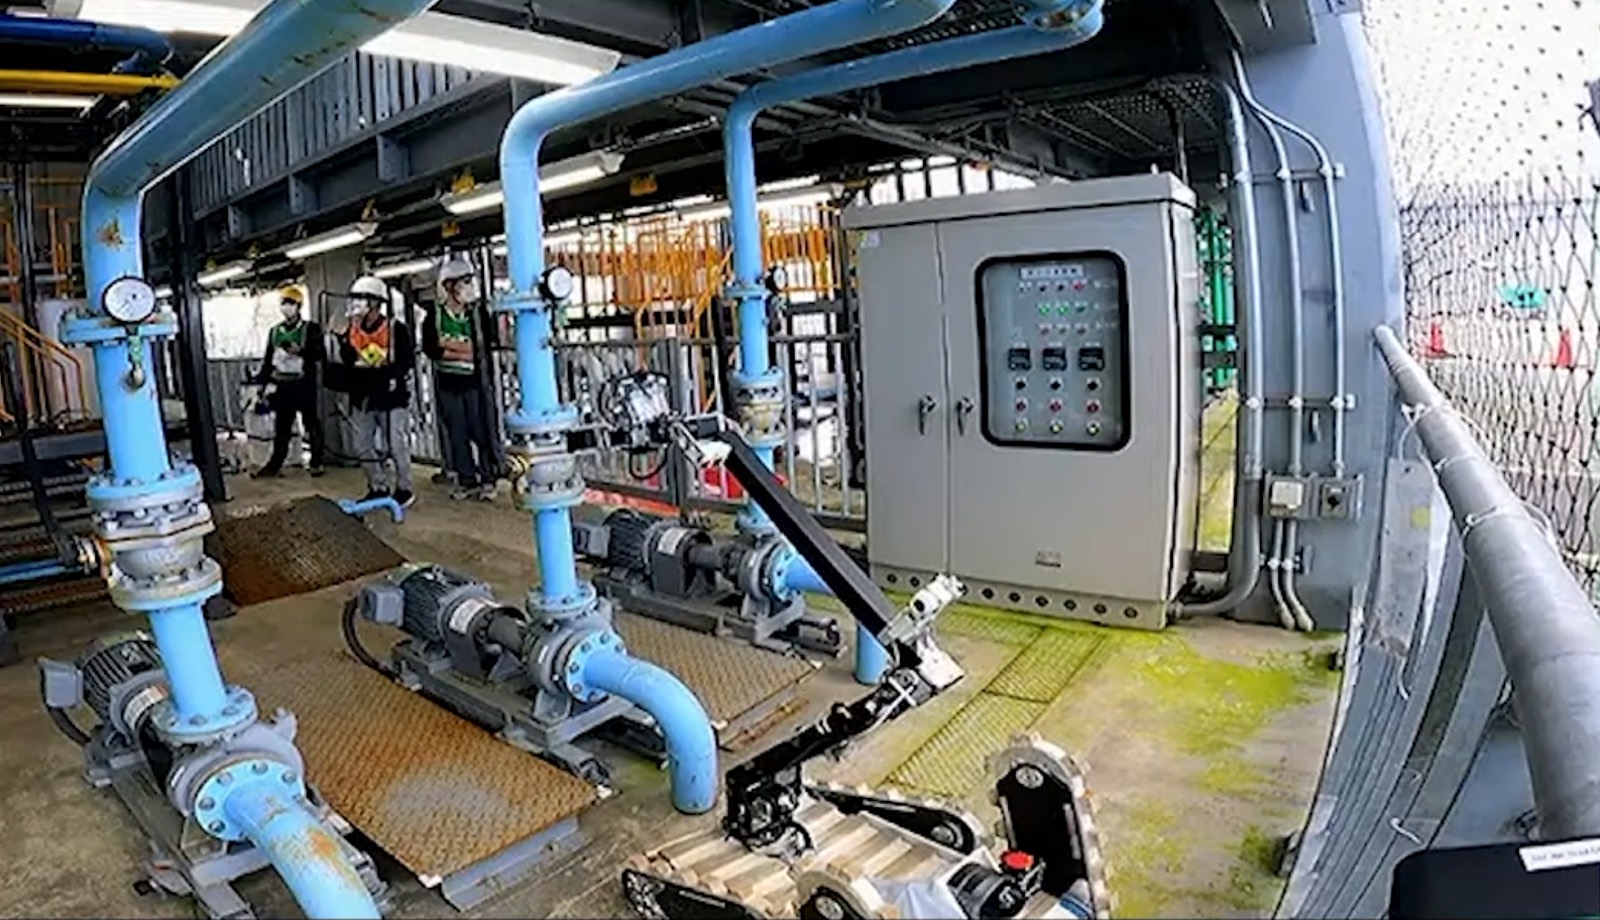
Disaster Prevention Challenge, World Robot Summit 2020
A heterogeneous robot team inspecting an industrial plant — the field test that made the coordination problem concrete.
Image: Ranulfo Bezerra
A multi-modal robot team — a tracked vehicle, a mecanum-wheeled vehicle, and a UAV, managed by two operators — competed in the Disaster Prevention Challenge at the World Robot Summit 2020, automating industrial plant inspection. Each platform proved good at something different: the tracked vehicle at mechanical tasks, the mecanum vehicle at rapid visual inspection in narrow passages, the UAV at aerial coverage. Making a team of unlike agents useful together, under time pressure and partial information, is the problem this site is about.